Humanoid Motion Learning Framework
Lightweight framework for learning humanoid control guided by reference motions.
Machine Learning & Robotics
I graduated from UC San Diego in 2025 with a B.S. in Computer Engineering. During my undergraduate studies, I served as the Software and Controls Team Lead for Triton Droids. Following graduation, I joined Venator Solutions as a Software Engineer / Algorithm Developer.
I am currently exploring engineering opportunities in robotics research / applied research.
Lightweight framework for learning humanoid control guided by reference motions.
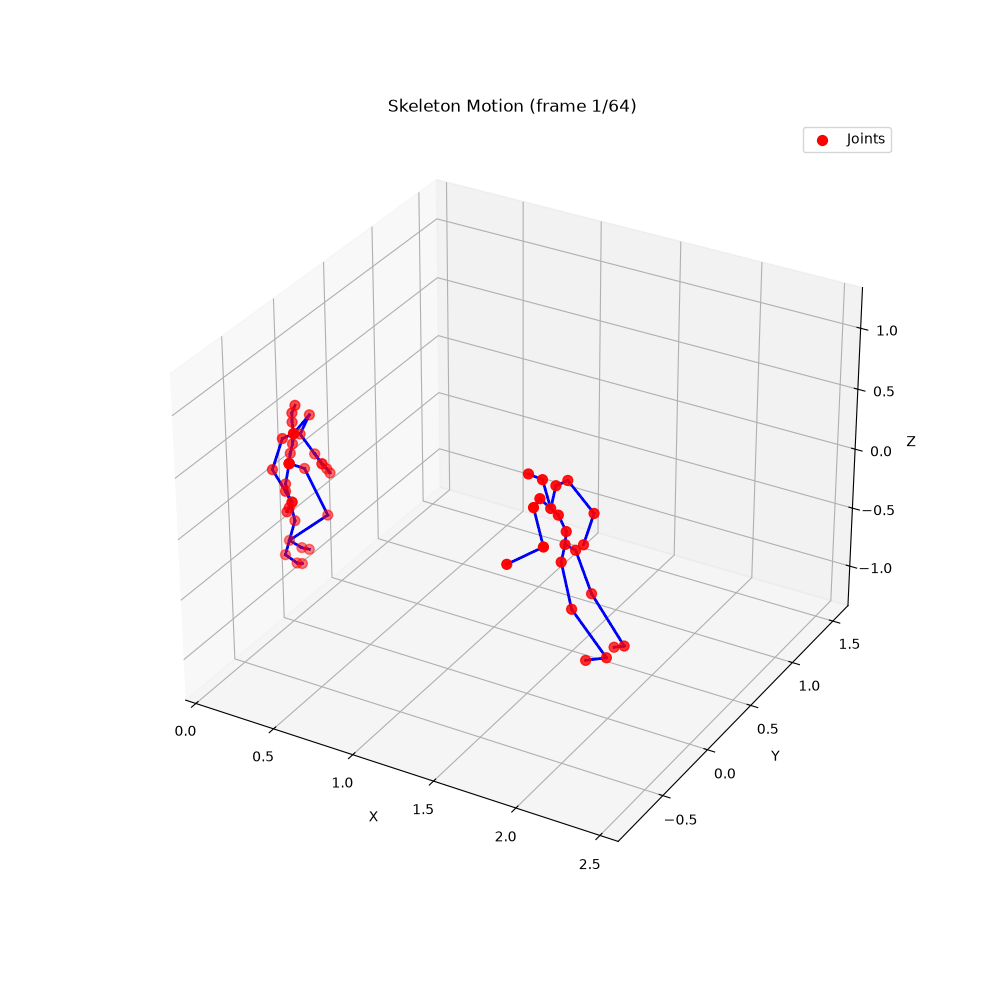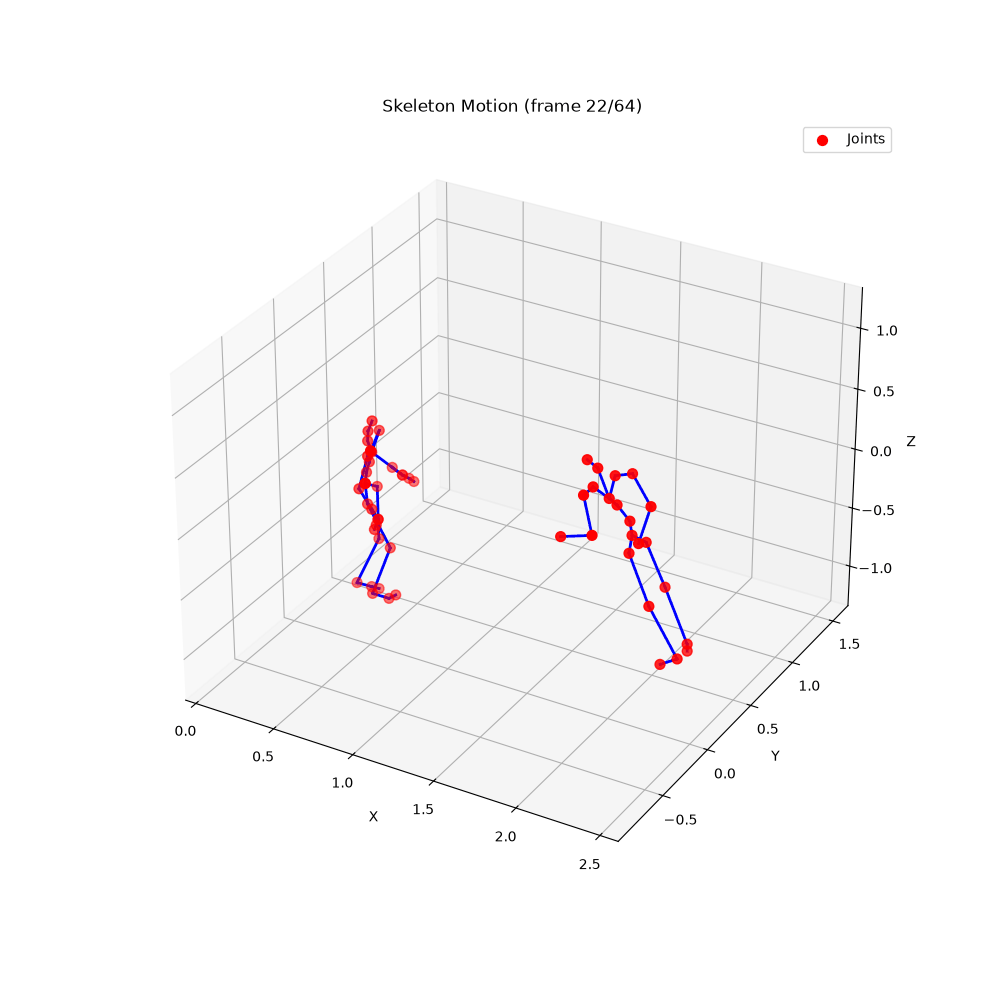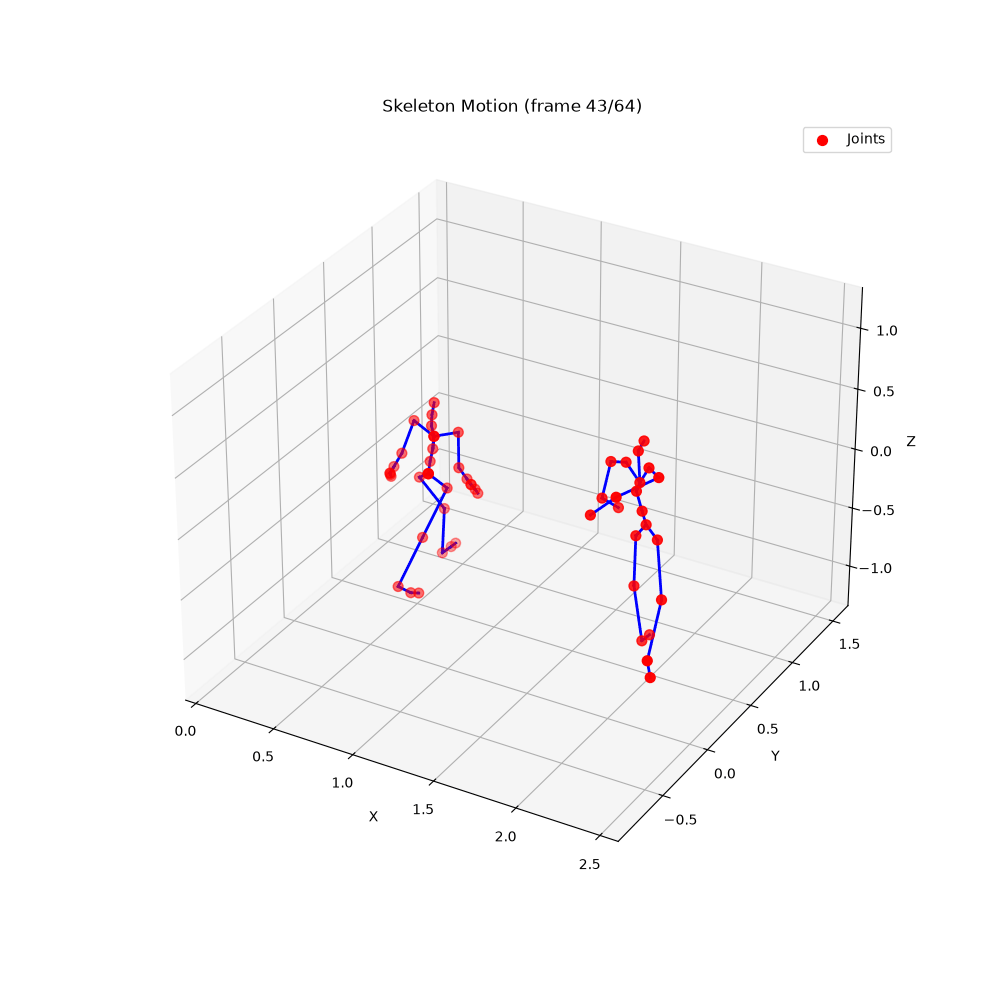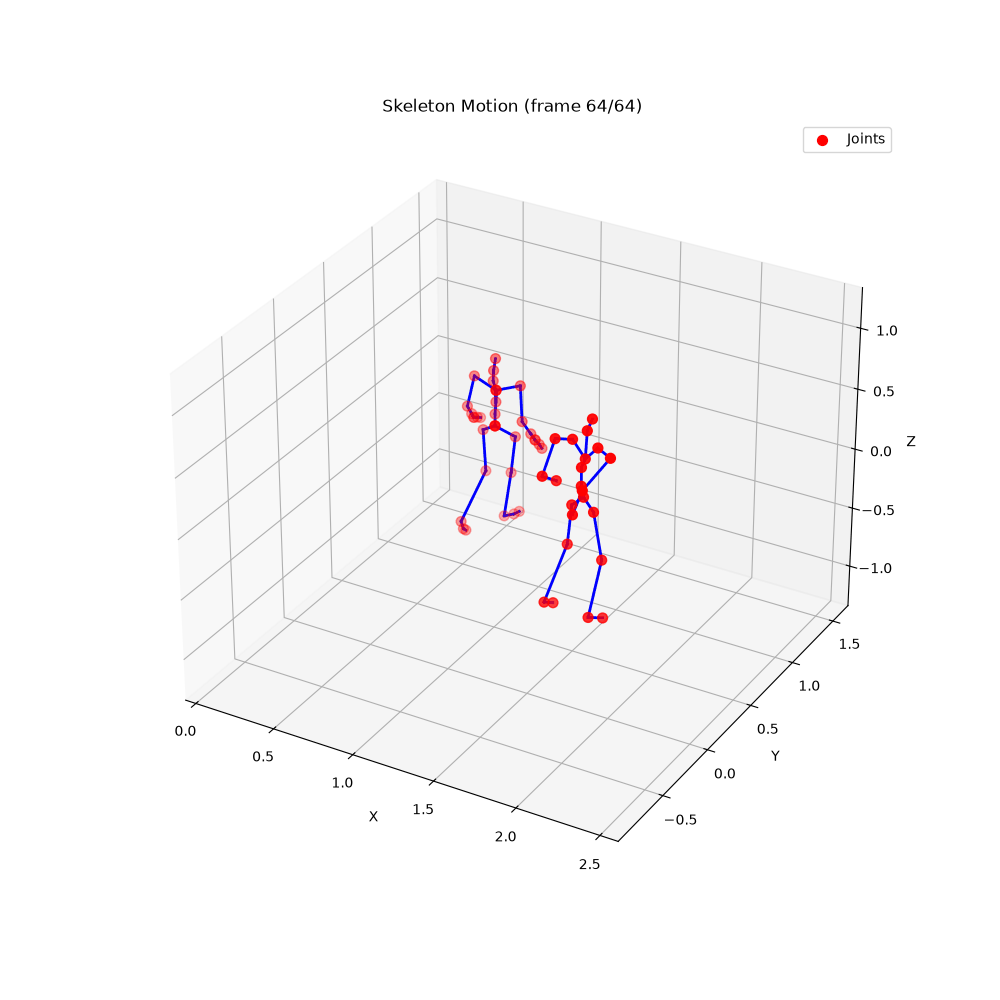
Retargeted motion data across any two motion domains ....
Reach me anytime at tonyroumi@gmail.com